Coverage
How much of the agreed route is completed?
The first robot · Greenhouse inspection
Our first robot does one job: it gathers comparable visual observations across a defined greenhouse area. In each pilot we measure how useful that record is to your team and what it takes to produce it.
Product in development
Each pilot starts in one defined growing area. A camera robot follows a planned route under your team's supervision, records what it sees and hands over a traceable inspection record.
Agree on the route, viewing points and inspection frequency with the team.
Capture views along the planned route and record completed coverage.
Locate observations by place and time, and decide what needs attention.
Compare the workflow with the current inspection routine and suitable alternatives.
Start with a small, standardised area and an agreed output. Set review criteria before the trial, including the human supervision and support needed to operate it.
How much of the agreed route is completed?
Are views clear, comparable and easy to locate?
How much supervision, intervention and maintenance does it need?
Does the record help the team make better-informed decisions?
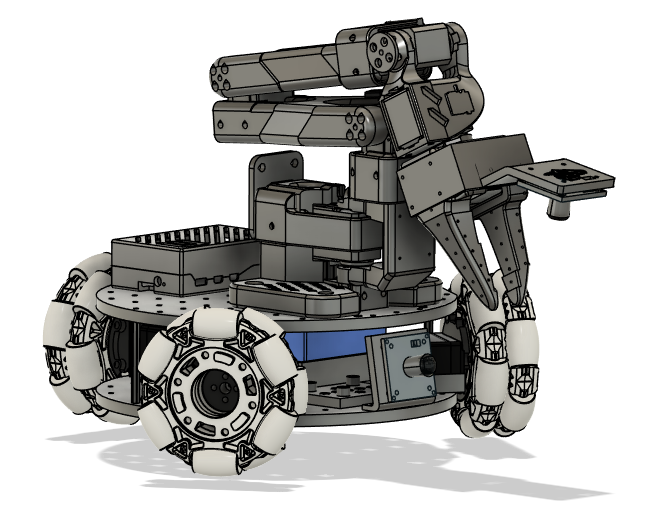
The development platform combines a LeKiwi mobile base, cameras and a SO-101 arm. Supervised visual inspection is the first use case. Sowing, transplanting, weeding and harvesting with task-specific tools follow on the roadmap. In greenhouses, OpenFactory is the operations architecture that will connect robot tasks with irrigation, nutrients and climate control.
Build the robot, the inspection workflow and the record it produces.
Test usefulness and operating effort in an agreed greenhouse setting.
Develop task-specific tools and OpenFactory integration as evidence guides expansion into nursery workflows and outdoor research.
Build with us
The work starts with a specific growing space, field question or investment thesis.